Update your robot software development frequency.

Get early access

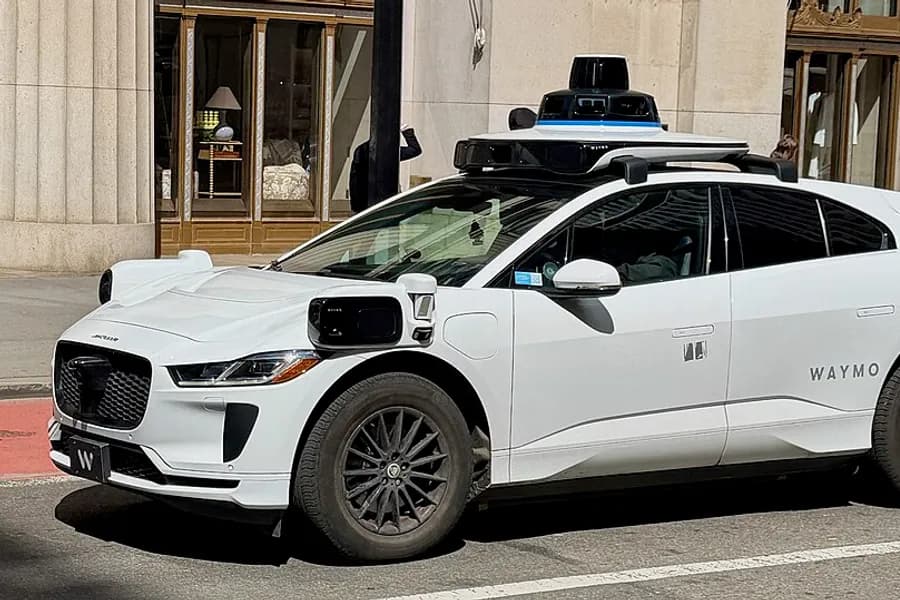
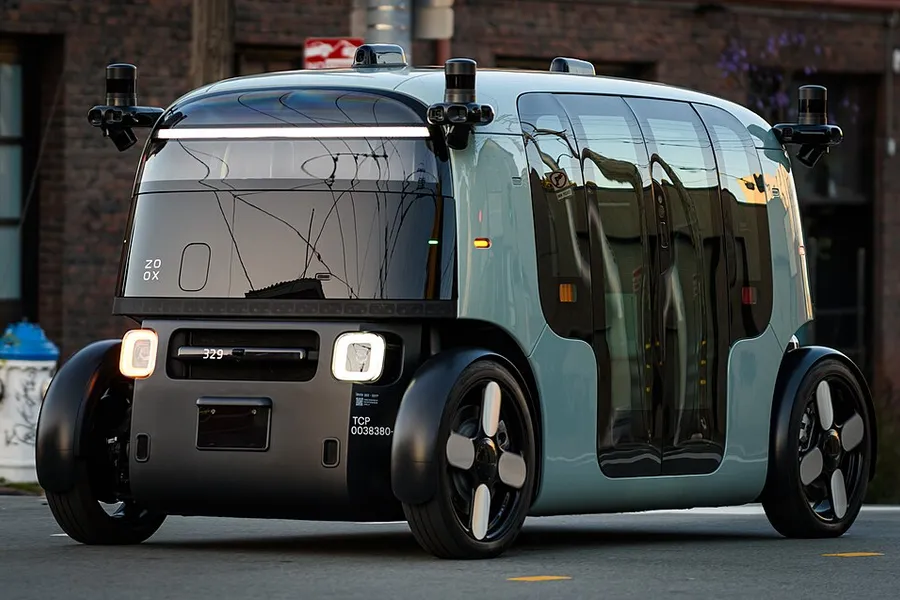
For mobile robots, robot arms, drones, self-driving cars, humanoids.

Write UPFREQ on the wall
Software·Runningupfreq/write-upfreq-7c21
Create PR
SimChanges 3ChecksLogs
Simulationhttp://localhost:5173/
Data Foxglove

Import any robot.

Drop in your robot's model. Upfreq checks every file, builds a simulation-ready digital twin, and writes down its interface so every agent knows the robot.
Painting robot
Robot · v2 · verified on your GPU
Preview in sim
Done
Files you dropped
painting_robot_description/
urdf/painting_robot.urdf.xacro1 file
meshes/28 files
config/ros2_control.yaml1 file
launch/2 files
Every mesh reference resolves.
What Upfreq found
KindMobile manipulator
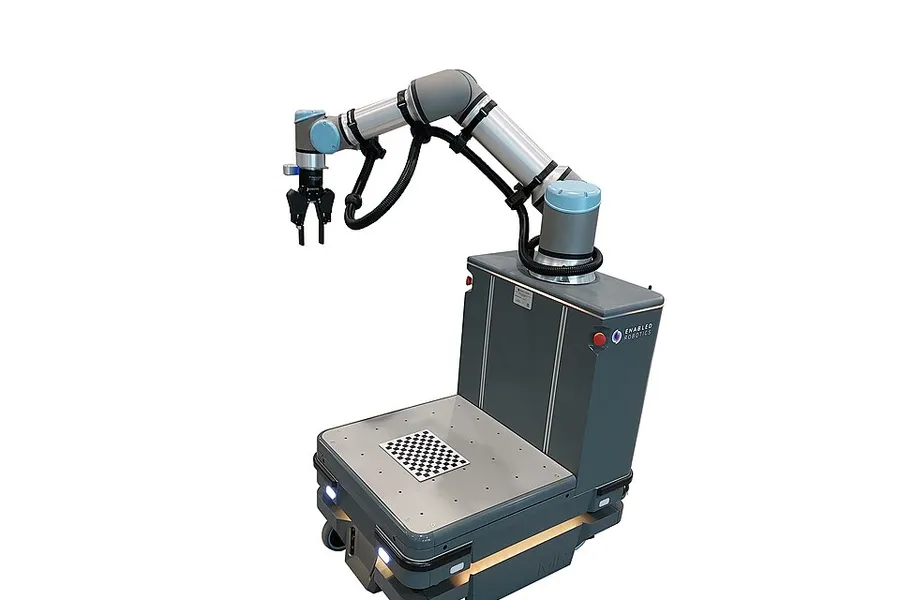
BaseMiR100 · 2 drive wheels
ArmUR5e · 6 joints, limits read
Sensors2 lidars · 1 camera
ROS 2 interface read by every agent
/cmd_vellistensgeometry_msgs/Twist
/joint_commandlistenssensor_msgs/JointState
/odompublishesnav_msgs/Odometry
/joint_statespublishessensor_msgs/JointState
/scanpublishessensor_msgs/LaserScan
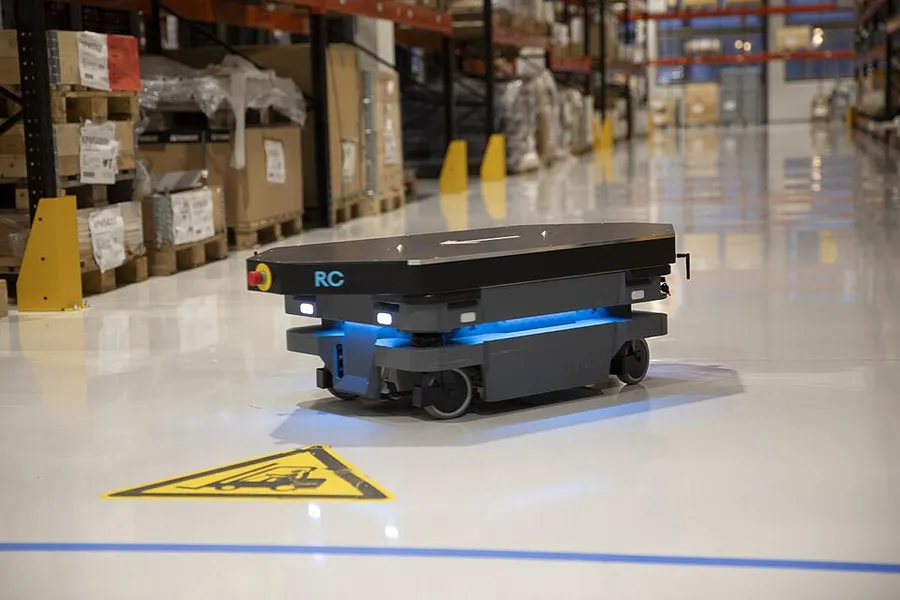
A MiR autonomous mobile robot in a warehouse
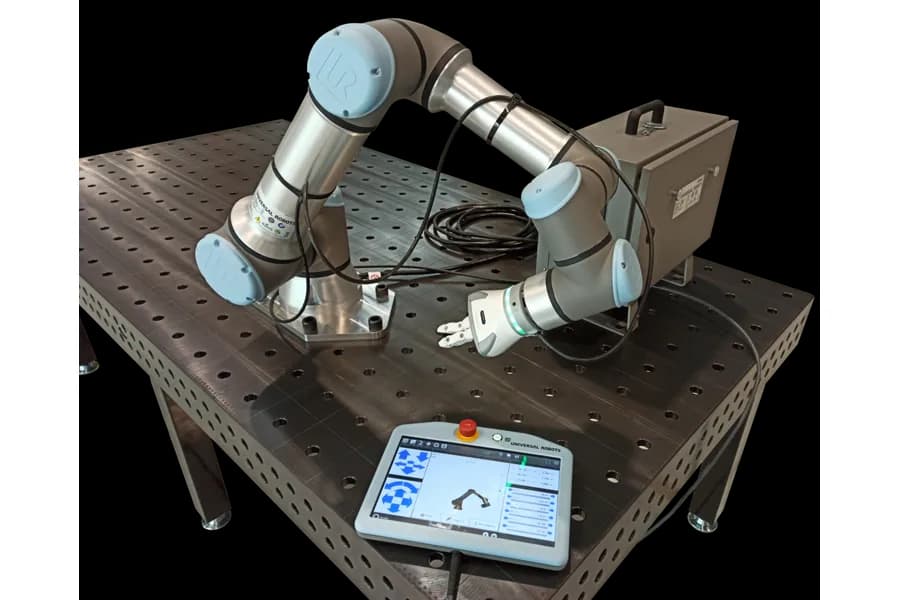
A mobile manipulator
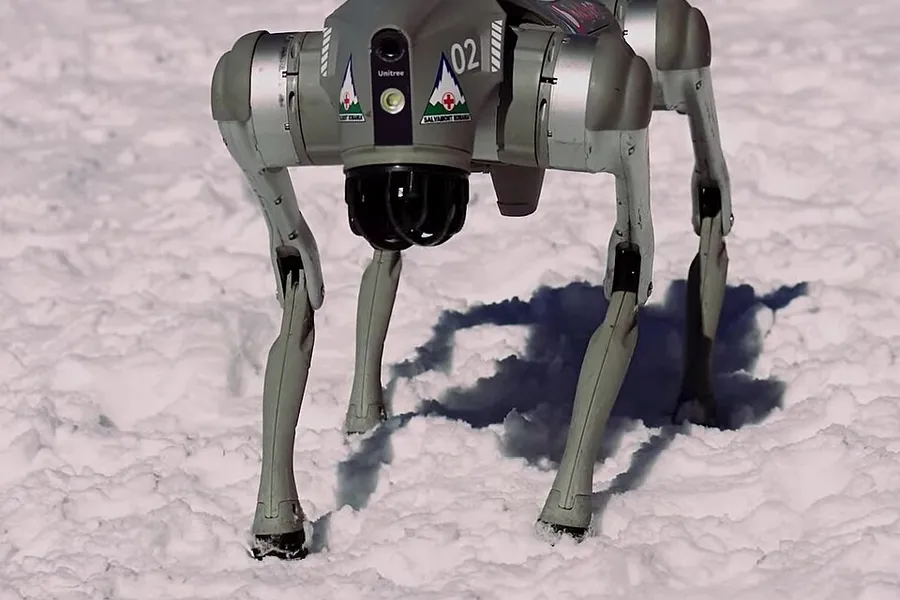
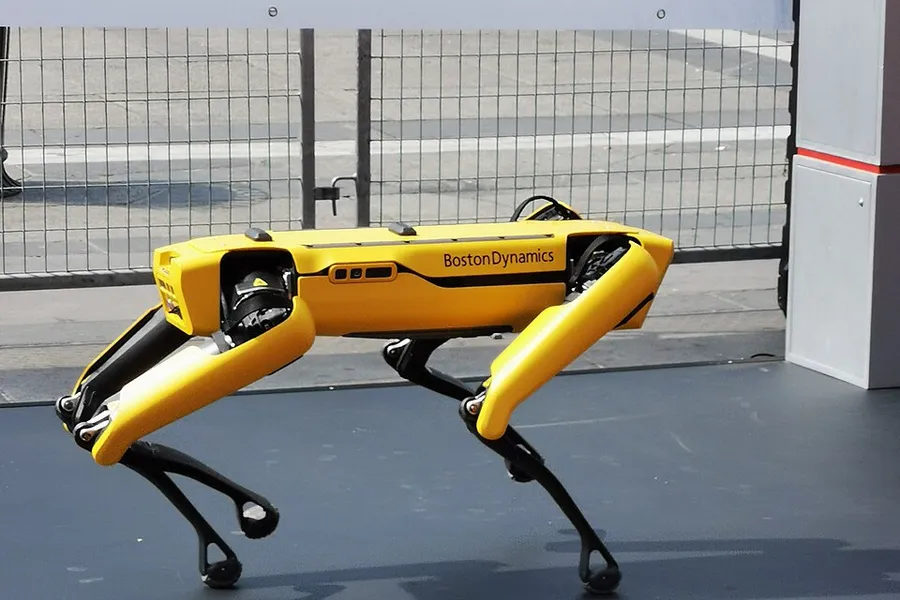
Mobile robots

Import environments.

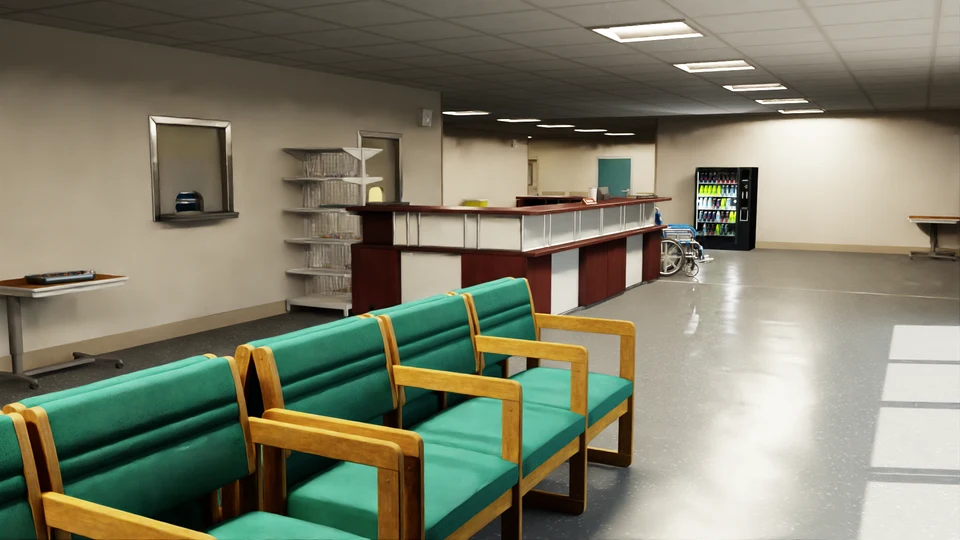
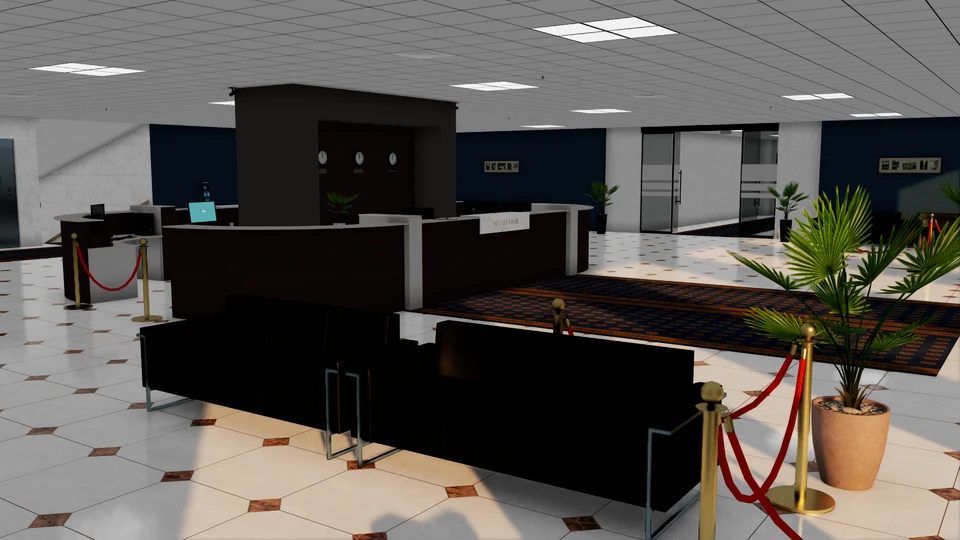
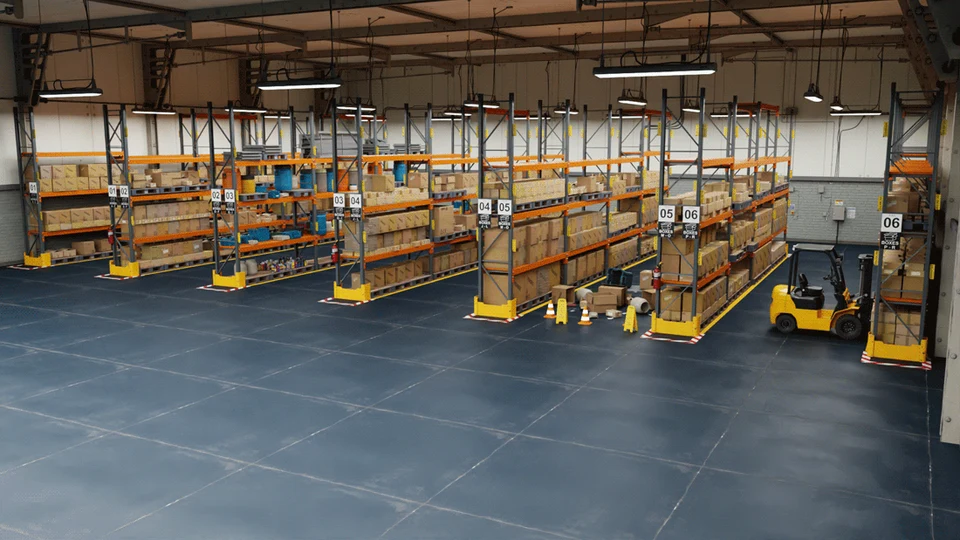
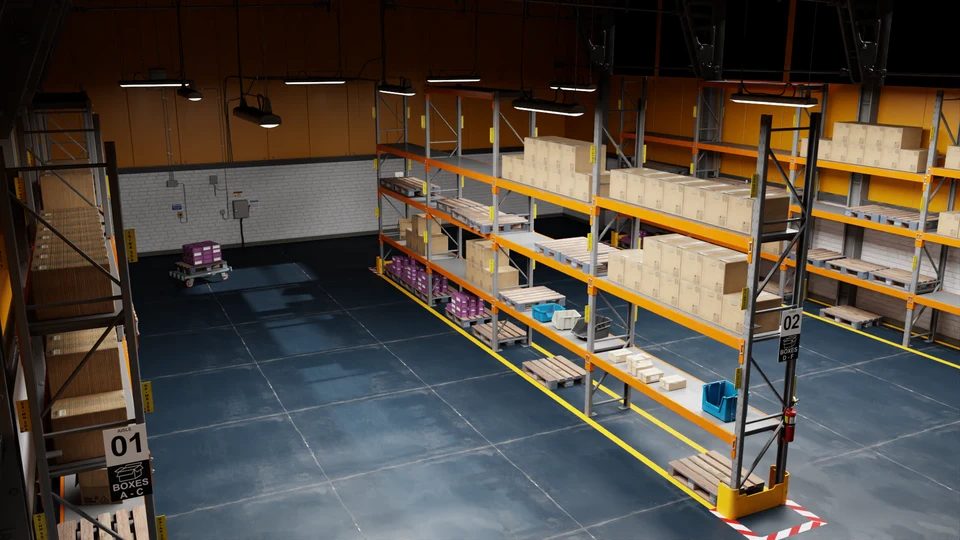
Start from warehouses, hospitals, offices and test tracks, or drop in your own 3D world. Upfreq checks it and gets it ready for simulation.
Environments
Assets · 10 built in · 1 of yours
Import USD
Full warehouseReady
Warehouse with shelvesReady
HospitalReady
OfficeReady
Simple roomReady
Grid roomReady
Your own
paint_wall_room.usd
12.4 MB · dropped just now
Opens in simulation
Units in metres, Z up
Colliders on 14 meshes
Syncing to your GPU
68%

Create a sim setup.

Put your robot in a world, place objects and pick where it starts. Upfreq checks it fits on your GPU and shows it live.

Painting robot at the paint wall
Sim setup · Running · preview on your GPU
Save & sync
Robot
Painting robot · mobile manipulator · v2
Environment
Paint wall roomFull warehouseHospitalOfficeGrid room
Objects in the scene
Paint wallx 2.0 y 0.0 ° 90
Paint bucketx 0.4 y -0.6 ° 0
Add object
Robot starts at
x 0.0 y 0.0 ° 0
Needs 3.1 GB of GPU memory · fits
Preview: the painting robot next to the paint wall Preview

Start working on your feature.

Describe what the robot should do. Here, the painting robot writes UPFREQ on the wall: the agent writes the code, tests it, and runs it in the live simulation.

Write UPFREQ on the wall
Software·Runningupfreq/write-upfreq-7c21
Create PR
SimChanges 3ChecksLogs
Simulationhttp://localhost:5173/
Data Foxglove

A whole team, side by side.

Every agent gets its own workspace, branch and ROS domain. Run several features at once on one GPU without them stepping on each other.

Painting robot · 4 agents
Sessions · each with its own workspace, branch and ROS domain
1 PR open
RTX 30609.4 / 12 GB · live sim 1/1 · workspaces 4/8
■ live sim■ code-only agents■ free
Write UPFREQ on the wall
upfreq/write-upfreq-7c21
Running in the live sim
Painting letter 4 of 6
own workspacedomain 7
LIVE SIM
Paint a straight stripe
upfreq/paint-stripe-41b0
12 tests passed
Ready for review
own workspacedomain 12
Stop for people near the wall
upfreq/stop-for-people-5d02
Writing code
Adding a lidar safety stop
own workspacedomain 23
Return to dock
upfreq/return-to-dock-9e3a
CI running
Pull request #14 open
own workspacedomain 31

Review, test, merge.

Agents open the pull request, answer your review comments, and fix CI when it breaks. You read the change and merge.
Paint a straight stripe
Software · upfreq/paint-stripe-41b0 · 3 commits
Merge
Changes+46 -3 · 3 files
painting_apps/stripe.py
18 def stripe_waypoints(length, height):
19- offset = 0.6
19+ offset = node.get_parameter("wall_offset").value
20+ steps = max(2, int(length / STEP))
21 return [(offset, y, height) for y in linspace(0, length, steps)]
You · line 19
Don't hard-code the wall offset, read the parameter.
Claude
Done. Reads wall_offset, default 0.6 m. Pushed 3f1a2c0.
Ready to merge.
Pull request
Paint a straight stripe #15open
CI checks
build1m 12s
testfailed → Fix CI → passed
lint14s
test_stripe_length failed in CI
Fix CI: Claude read the job log, fixed the length rounding, pushed, CI passed.

Update your robot
development frequency.

Get early access